Industry · process
Logistics and distribution
Tests picking items whose positions change every time using a camera, and delivery robots stopping precisely at set points.
These are example processes. The results below are simulation tests; tests with your actual goods and site are run as a custom validation request.
Simulation view
Processes
Example processes
Tests
Tests for these processes
Select a test to go to its results.
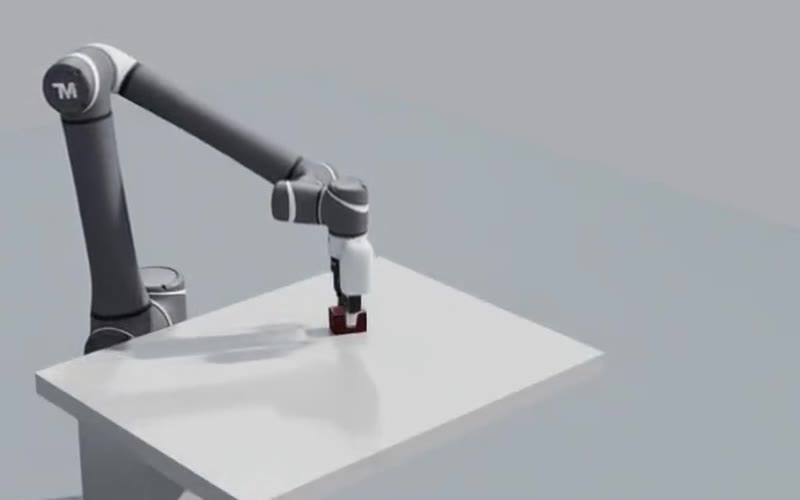
Simulation view · Pick and place — find by itself at random positions
Pick and place — find by itself at random positions
Success rate of the robot finding an object at a random position within a defined range with its camera, grasping it and placing it at a defined spot — ground-truth object position used only for scoring (not for motion)
Public results for this test
Simulation view · Pick and place — fixed position
Pick and place — fixed position
Path-planned grasping and moving of an object at a fixed position, and contact forces
Public results for this test
Simulation view · Precision stop at parcel locker
Precision stop at parcel locker
Position and heading error when stopping at the assigned locker compartment.
Example result for this test