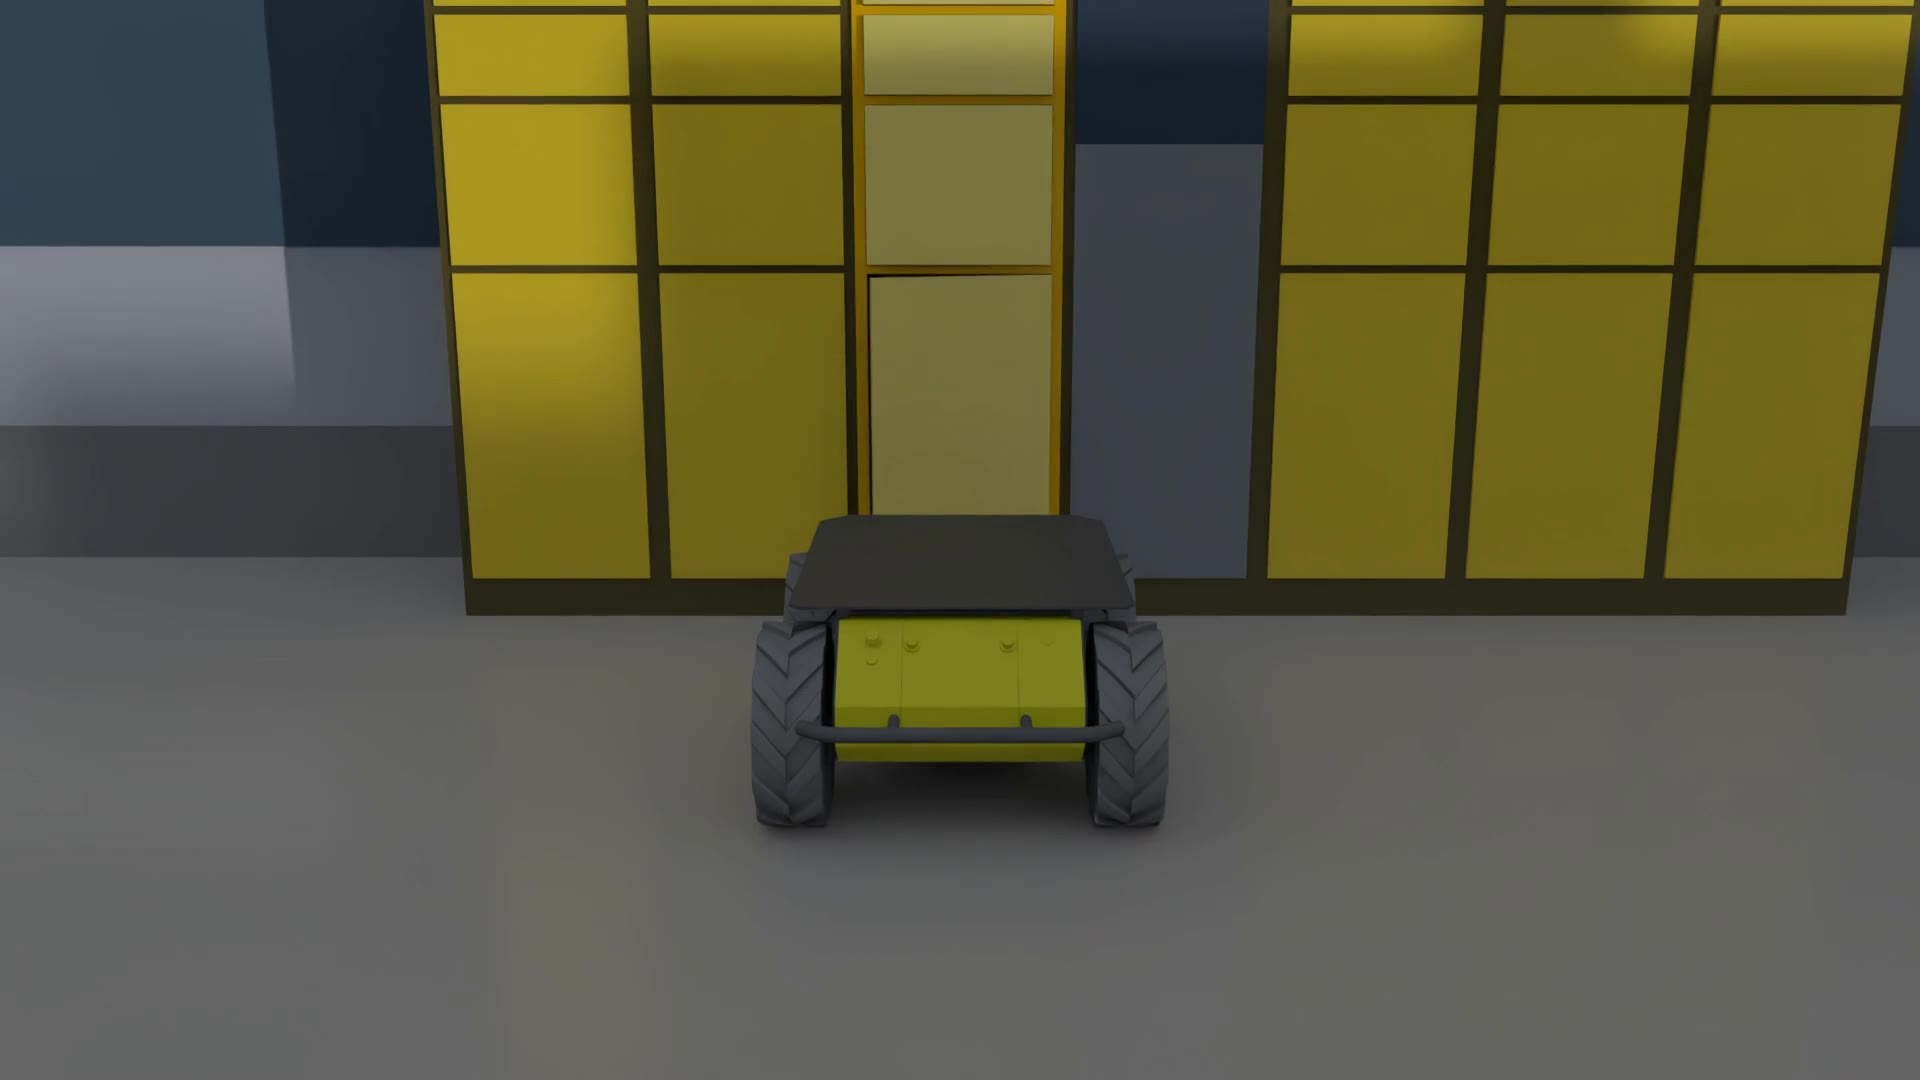
Simulation view · Precision stop at parcel locker
Example results
Measured on 2026-10-12 · imSim common verdict criteria v1
Precision stop at parcel locker
PassThe robot starts from the stop point at the delivery site, travels along the sidewalk and stops in front of the assigned compartment of the parcel locker. When it stops, the locker unlocks that compartment's door (the door opens slightly).
8 of 8 verdict items passed · same verdict across 3 repeated runs of the same test
| Item | Criterion | Measured | Verdicts |
|---|---|---|---|
| Abnormal terminationCriterion 0 | 0 | 0 | Pass |
| CollisionCriterion 0 | 0 | 0 | Pass |
| Near missCriterion 2 or fewer | 2 or fewer | 0 | Pass |
| Emergency stopCriterion 5 or fewer | 5 or fewer | 0 times | Pass |
| AnomaliesCriterion 3 or fewer | 3 or fewer | 0 | Pass |
| Minimum distance to obstaclesCriterion 1.00 m or more · Wheeled mobile robot defaultWhile stopped in front of a work target such as the parcel locker, that target is excluded from the measurement. Including it, the value is 0.95 m. | 1.00 m or moreWheeled mobile robot default | 1.42 m | Pass |
| Maximum speedCriterion 2.00 m/s or less · Wheeled mobile robot default | 2.00 m/s or lessWheeled mobile robot default | 0.98 m/s | Pass |
| Maximum tiltCriterion 45.0° or less · Wheeled mobile robot default | 45.0° or lessWheeled mobile robot default | 7.7° | Pass |
Scenario's own summary: Pass — not scored by the judge; the overall verdict takes the worse of this and the items above.
Values measured in this test (not verdict items)
5.7 mm
Maximum position error while holding the stop in front of the compartment
0.01°
Maximum heading error over the same period
0.0 s
Time outside the tolerance band
- The robot was driven by a human-designed scripted controller (predefined motions), not by a trained AI.
- A wheeled outdoor robot platform was used as a stand-in.
- Some site dimensions, lift and compartment door actuation values are assumed. Parcel handover is not yet included.
- The thresholds are imSim common defaults used in all domains and wheeled mobile robot defaults. They are not pass thresholds tailored to delivery robots.
- The precision stop error is measured by the scenario and is not a verdict item.
- These are simulation results and do not replace physical testing.